The fastest path to a first successful cobot cell starts with the application, not the arm: most first-time buyers waste weeks comparing spec sheets on hardware that does not match the job they actually need to automate [S3].
A first cell should run a task that is repetitive, low-hazard, and tolerant of a few hundredths of a millimetre, with payload in the 3-30 kg band, reach in the 620-1,800 mm range, and repeatability at or near ±0.02 mm on the latest models [S5]. ISO 10218-2:2025 has folded ISO/TS 15066's collaborative-operation rules into the main standard and replaced the term "cobot" with "collaborative application", meaning compliance is about how the cell is deployed, not just what is bolted to the floor [S5].
Start With the Application, Not the Payload Number
Choosing a cobot by looking at the heaviest SKU on the price list is the most common first mistake, and it usually locks the buyer into a 30 kg arm they will never load past 5 kg [S3]. A 2026 selection guide ranks payload as step one of a five-step framework, but it is payload of the *task* (part mass plus end-effector plus margin), not the marketing maximum [S5]. For a first cell, that almost always lands in the 3-12 kg range, where the bulk of global deployments sit [S5].
Look for a task that is "repetitive enough to matter, simple enough to deploy, and visible enough to learn from", per a May 2026 integrator guide [S3]. Machine tending of a single CNC, a screwdriving station with a fixed fastener pattern, or a pick-and-place transfer between two conveyors are typical first candidates. Tasks that involve instant human-style decisions, fine in-cycle judgement, or contact with deformable parts should stay manual until the team has at least one cell running. The rule of thumb from that same guide: if a person can do it 200 times an hour without thinking, a cobot can do it 8,000 times an hour without breaking.
Payload, Reach, Repeatability: The Three Specs That Actually Decide the Winner
Payload tiers in 2026 split cleanly into three bands, each with a typical reach envelope: light-duty ≤6 kg (reach 620-924 mm), medium-duty 6-12 kg (reach 900-1,500 mm), and heavy-duty 12-30 kg (reach up to 1,800 mm) [S5]. The 6-12 kg band is the highest-demand segment because it covers welding, painting, machine tending, and light palletizing in one envelope, and it is where most first cells land.
Repeatability is the second number that quietly kills projects. The newest cobots quote ±0.02 mm at the tool centre point, which is competitive with much larger industrial arms, and a small number is better, but it is also more expensive, so opening the tolerance where the application allows it (e.g. ±0.1 mm for a dispensing or palletizing cell) opens the door to lower-cost arms [S1][S5]. A practical comparison for a first cell:
Selection criteria, three common cobot classes, side-by-side:
Light-duty (≤6 kg, 620-924 mm reach): best for electronics assembly, screwdriving, inspection; lowest cost, smallest footprint, easiest bench-mount install; repeatability typically ±0.03 to ±0.05 mm.
Medium-duty (6-12 kg, 900-1,500 mm reach): best for CNC tending, light welding, packaging, and lab automation; the segment with the widest accessory ecosystem and shortest lead times; repeatability often ±0.02 to ±0.05 mm.
Heavy-duty (12-30 kg, up to 1,800 mm reach): best for palletizing, large-part handling, and metal finishing; above-10 kg models are forecast to grow at a CAGR above 24% through 2033 on automotive and metalworking demand; heavier base, higher TCP inertia, often needs a fixed pedestal rather than a bench mount [S5].
Force-Limited vs Force-Controlled, and Why the Wrist Geometry Matters
All cobots are force-limited (they stop on collision), but not all are force-controlled (they can use a force signal as a process input), per SwRI's 2021 selection guide [S1]. For a first cell where the goal is simple material handling, force-limited is enough. If the eventual plan is assembly with insertion force feedback, surface finishing, or compliant deburring, the buyer needs a cobot with high-resolution, low-latency force feedback usable inside the controller, not just an external F/T sensor bolted at the wrist [S1][S4].
Joint configuration is a second pitfall. Many cobot arms use an eccentric (offset) wrist to free up payload, but that geometry moves the end-effector through a long arc for short Cartesian moves, which complicates cable management and can cause trouble in tight fixturing [S1]. For a first cell with a single fixture and a clean dress pack, this rarely matters; for cells that will be redeployed across multiple workstations, an inline wrist or a documented cable-management solution is worth the extra spec check [S1].
Ease of Programming: Drag-and-Teach vs Pendant, and the Out-of-Box Test
Cobots are sold on simplicity, but the spread between the easiest and the hardest to commission is wide: some plug in and teach in minutes, others have a setup complexity closer to a traditional 6-axis industrial robot [S1]. For a first project where the operations team has no robot experience, the practical test is whether the supplier will demo the arm in person or on video, and whether the teach pendant runs a graphical drag-and-drop flow or a script-style programming language.
For research and high-mix work, ROS support and a 1 kHz (1 ms) communication rate are differentiators, since they let the arm participate in HRI, vision servoing, or closed-loop force experiments that a closed vendor stack cannot [S4]. For a first production cell, the better filter is the size of the user community and the depth of the certified integrator network, not the open-API brochure, because cell downtime costs more than the arm itself.
Safety, Standards, and the Risk Assessment You Cannot Skip
ISO/TS 15066 established the four collaborative operation modes (safety-rated monitored stop, hand guiding, speed and separation monitoring, and power and force limiting), and the updated ISO 10218-2:2025 has now absorbed those requirements and reframed the whole problem as a "collaborative application" rather than a "cobot" [S5]. Power and force limiting (PFL) is the mode most first cells use, and it caps the tool-centre-point speed and the quasi-static contact force per body region. The buyer should be ready to run an ISO 12100 risk assessment for the cell, not just the arm, before the integrator delivers a robot.
For buyers in Europe, the relevant conformity route is the Machinery Regulation (EU) 2023/1230 with ISO/TS 15066 / ISO 10218-2 used for the collaborative-operation layer, and a CE-marked risk assessment file at handover. For North American buyers, ANSI/RIA R15.06-2012 plus the R15.606-2016 collaborative addendum is the working pair. A common first-project mistake is treating the cobot's built-in safety as a substitute for a documented cell risk assessment; it is not, and a recorded risk assessment is a deliverable the integrator should hand over with the cell.
Ecosystem, Lead Time, and the "Two Capabilities" Question
A first cell does not just need an arm, it needs an ecosystem: end-of-arm tooling, safety scanners, signal towers, the fieldbus I/O that talks to the host machine, and a programmer who can integrate the cell [S3]. The most widely-deployed cobot platform in North America is also the brand most often specified into first-time installations, and a key reason is accessory breadth, not arm kinematics [S3].
Buyers should also split "platform capability" (knowing the product line, lead times, end-of-life SKUs, accessory cross-references) from "application capability" (cell design, fixturing, programming, risk assessment, training), because a single supplier covering both is faster for simple cells, while a specialist integrator adds value on cells where application depth matters (e.g. medical-device assembly vs injection-mould tending) [S3]. For a first cell on a budget, the platform-heavy route is usually the cheapest; for a first cell on a regulated line, the application-heavy route usually pays for itself.
Common First-Cell Pitfalls and What to Verify Before Signing
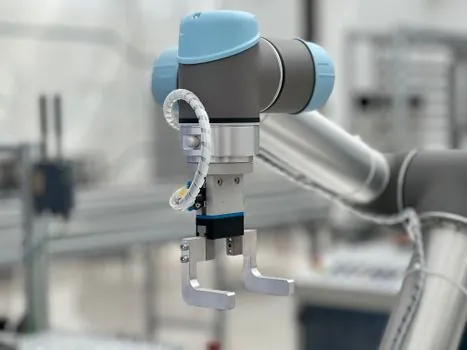
Three pitfalls show up across every 2026 selection guide. First, payload is rated at maximum reach with a specific wrist pose, so the actual usable payload at the working pose is often 20-30% lower than the headline number, and end-effector weight eats into the budget faster than expected [S1][S4]. Second, repeatability numbers assume a warmed-up arm on a rigid mount; bolted to a workbench that flexes, real numbers drift. Third, "collaborative" does not mean "no risk assessment"; a PFL cell still needs a documented ISO 12100 review, a defined collaborative workspace, and a stop category that the safety scanner can actually trigger.
Trackable signals for a first cell going in: lead time on the chosen arm SKU (12-16 weeks is common on medium-duty models in 2026, with light-duty often in stock), availability of a local certified integrator within driving distance, and whether the supplier will provide a remote or in-person commissioning slot. For a deeper read on the safety side, see Cobot PFL speed limits: 250 mm/s TCP cap, force thresholds, and the 2025 standards reset; for a structured risk-assessment workflow, see Cobot Risk Assessment: ISO 12100 Five-Step Workflow for a New Cell. Also worth knowing for adjacent cells: an air impact wrench on a torque-and-verify station, or a pneumatic nail gun on a sub-assembly line, are common downstream tools that pair cleanly with a 6-12 kg cobot for a first screwdriving or fastening cell.