ANSI/ITSDF B56.5-2024 is the active U.S. safety standard for driverless, automatic guided industrial vehicles and for the automated functions of manned industrial trucks, with the 2024 edition superseding the 2019 release [S1][S6].
The document is published by the Industrial Truck Safety Development Foundation (ITSDF) and administered through ANSI; it is a voluntary consensus standard that OSHA references when evaluating industrial-truck citations in the United States [S1][S3].
Scope: What B56.5-2024 Covers, and What It Deliberately Excludes
B56.5-2024 covers unmanned guided industrial vehicles (AGVs) plus the automated functions added to manned industrial trucks, such as forklifts that slow or stop automatically when a hazard is detected [S2][S6]. The 2019 revision explicitly rescoped the document so it does not apply to vehicles operating in closed areas where personnel are not allowed and where appropriate interlocking systems, safeguards, and procedures are in place, which keeps purely isolated-robot cells from being regulated as AGVs [S4].
For U.S. buyers, this scope means a tugger, unit-load, or forklift-style AGV operating in mixed-traffic aisles is squarely inside B56.5; a robot fenced behind light curtains with access interlocks is not, and falls under other OSHA machinery rules instead [S3][S4]. The paired machine safety reference gives the broader machinery-risk context that the AGV standard plugs into.
Hazard Zones, Speeds, and Clearance Distances
B56.5 Table 1 (Summary of Operating Speeds and Requirements in Hazard Zones and Restricted Areas) sets the engineering limits, with hazard-zone vehicle speed capped near 1.2 m/s (about 2.6 mph) and restricted-area speed limited to 0.3 m/s (about 0.6 mph) where guidepath clearance is inadequate and no escape route exists [S4]. A Very Narrow Aisle (VNA) restricted area is defined as a path bounded by fixed continuous racking with less than 0.5 m clearance on both sides, where unauthorized personnel are prohibited [S4].
These numbers drive the minimum clearance dimensions, the placement of object detectors, and the speed-map a fleet-management system has to enforce on every mission; they are not guidance, they are the test points an OSHA inspector or third-party validator will look for. Teams already running mixed-traffic fleets should compare their current speed zoning against this table as a first compliance check [S3][S4].
Object Detection, Test Pieces, and the Three-Zone Sensing Model
B56.5-2019 introduced the modern object-detection framework, including definitions for non-contact sensing devices and standardized test pieces (commonly referenced as a, b, c) that the vehicle's perception system must reliably detect [S4]. The 2024 edition carries that forward with refinements tied to mixed-traffic, human-coexistence operation [S1][S5].
A practical implementation lines up with the three-zone sensing model used across the industry: a warning field (slow the vehicle), a protective field (stop the vehicle before contact), and a contact/emergency layer (hard stop on physical encounter) [S5]. A typical safety laser scanner on a tugger-class AGV is configured with roughly a 2 m protective field, an 8 m warning field, and a 30 m maximum detection envelope, with the protective stop and the emergency stop treated as separate, independently wired safety functions [S5]. The safety barrier reference covers the physical layer these sensors protect.
ANSI B56.5 vs ISO 3691-4 vs UL 3100: A Criteria Comparison
ANSI B56.5-2024 is voluntary in the U.S. and OSHA-referenced, while ISO 3691-4 is mandatory for CE marking in the EU and is adopted in more than 160 countries; UL 3100 is the U.S. standard that brings AGVs and autonomous mobile robots (AMRs) under a single automated-mobile-platform framework [S3][S5]. ISO 3691-4 is structured as a Type C machine standard and requires formal hazard analysis aligned with ISO 12100 plus Performance Level (PL) ratings for safety functions; B56.5 covers the full lifecycle (design, testing, installation, operations) at a system level across vehicle, facility, and people [S3].
On four decision criteria for a multi-market fleet, the comparison reads roughly: regulatory weight (ISO 3691-4 highest, ANSI B56.5 voluntary but OSHA-cited, UL 3100 mobile-platform layer); hazard-analysis rigor (ISO 12100 mandated under ISO 3691-4, risk assessment required under B56.5 but framed for U.S. practice); sensing and safety-function specification (ISO 3691-4 with PL ratings, B56.5 with test-piece and zone-speed tables, UL 3100 covering the platform); and applicability to AMRs (ISO 3691-4 limited to driverless industrial trucks, B56.5 focused on AGVs and automated manned-truck functions, UL 3100 explicitly both AGVs and AMRs) [S3][S5]. For a U.S.-only fleet, B56.5-2024 plus UL 3100 is the common pair; for a product that ships to the EU, ISO 3691-4 with ISO 12100 hazard analysis becomes non-negotiable [S3][S5].
E-Stops, Audible/Visual Warnings, and Speed Limiting
B56.5 requires accessible, clearly marked emergency-stop devices that bring the vehicle to an immediate halt, with human intervention required to resume operation, meaning no automatic restart after an e-stop event [S3]. Audible and visual alerts must notify nearby workers of vehicle presence and movement, and must meet minimum brightness and decibel thresholds suitable for industrial ambient noise [S3].
Speed must be controlled relative to the vehicle's detection capability and load, with automatic reduction in high-traffic or restricted-clearance zones, and paths must be clearly defined and controlled within the facility layout [S3]. The fire safety and safety fence references are useful when an AGV route runs adjacent to a fire-rated wall or guarded machine cell, since B56.5 zoning rules often interact with those physical safeguards.
NIST Test Methods and the Path Toward Standardized Validation
NIST's Mobile Autonomous Vehicle Obstacle Detection/Avoidance (MAVODA) project is developing test methods to assess safety when humans enter or reside in the path of an AGV or a manned truck with automated functions, building measurement science for the B56.5 committee to use in evaluating both non-contact and contact sensing systems [S2]. Published error rates for vision and infra-red pedestrian detectors in area applications have ranged from 9% to 39%, which is part of why NIST's test-method work is feeding into the standard rather than being left to each integrator to reinvent [S2].
The underlying safety case for AGVs is the forklift-injury record they replace: U.S. Bureau of Labor Statistics data from 2011 to 2017 lists 614 worker fatalities in forklift-related incidents, the National Safety Council's Injury Facts recorded 84 work-related forklift deaths in 2024 and 25,110 DART cases in the 2023-2024 reporting period, and OSHA reports that roughly 80% of forklift incidents involve a pedestrian [S5]. A properly integrated AGV line removes most of the operator-fatigue and inattention failure modes behind those numbers, but only when the B56.5 zoning, sensor configuration, and training elements are explicitly specified [S5].
Who B56.5-2024 Is For, and Where It Stops Being the Right Standard
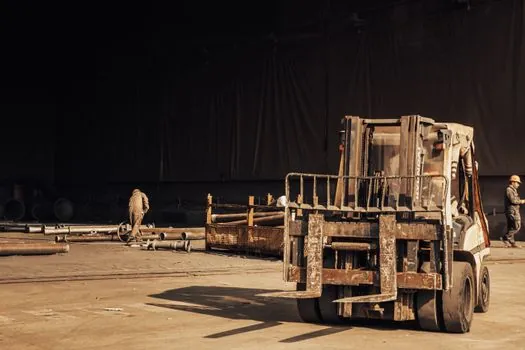
B56.5-2024 is the right reference for North American end users specifying AGVs, for system integrators building mixed-traffic fleets, and for OEMs selling driverless industrial trucks into U.S. and Canadian facilities [S1][S3]. It is the wrong reference for products shipping into the EU, where ISO 3691-4 plus ISO 12100 and the Machinery Directive are the legal pathway, and it is the wrong reference for a pure autonomous mobile robot operating without a fixed guidepath in a fully unstructured space, where UL 3100 and emerging AMR guidance apply [S3][S5].
For a new U.S. build, the practical compliance sequence is: run the B56.5 hazard-zone analysis first to set speed limits and clearance dimensions, then specify the three-zone sensor set against the 2 m / 8 m / 30 m envelope as a starting point, then map the e-stop, warning, and braking safety functions to a defined PL or equivalent rating, and finally validate with documented test-piece trials consistent with NIST MAVODA-style methods [S2][S3][S5]. A useful sanity check is to walk the route with the safety certification reference open and confirm every hazard zone has a matching object detector and a posted restricted-area speed.
For a fleet already running B56.5-2019 hardware, the watch-items for the 2026 cycle are: confirm the documented edition on file is B56.5-2024 rather than the 2019 release, re-verify Table 1 zoning against the current aisle dimensions after any layout change, and capture test-piece detection logs from the past 12 months as the audit trail for the updated edition [S1][S4][S6]. The most useful next signal is UL 3100's uptake by U.S. AMR vendors through the rest of 2026, since AMR-class machines increasingly share AGV aisles and will pull UL 3100 into the same compliance review as B56.5-2024 [S3][S5].
See also our earlier report, Underride lift AGV vs conveyor-top AGV: a 2026 spec-driven pick.