A cobot cell cannot be commissioned until a documented risk assessment is complete, because ISO 10218-2 makes the assessment the gating artifact for every downstream safety decision including which collaborative mode applies, which body regions must be contact-tested, and where to position measurement equipment [S1].
The assessment is run under the ISO 12100 five-step process, and the output of each step feeds the next until residual risk meets documented tolerability criteria; a single iteration is rarely enough on a new cell [S1].
Step 1: Define Machine Limits and Use Specification
Step 1 fixes the boundary of the assessment: intended use, spatial limits (reach envelope, adjacent work areas), time limits (design life, maintenance intervals), and named operator roles [S1]. Specificity matters here, because vague limits force vague hazards later. 'Pick-and-place aluminum housings, max 2 kg payload, operator standing 400 mm from robot base, single-shift operation' is auditable; 'cobot cell' is not [S1]. The use specification is also the input for cell layout, and a related reference on workspace reach planning covers the six-axis versus seven-axis reach trade-off that follows from it. Note that ISO/TS 15066 is the technical specification referenced for collaborative operation thresholds, not ISO 12100 itself, which is the general risk methodology [S1].
Step 2: Identify Hazards Across Every Operating Mode
Every operating mode must be walked through, not just normal production: teaching/programming, maintenance, cleaning, fault recovery, and emergency stop recovery are all part of the hazard set [S1]. Standard hazard categories apply: mechanical, electrical, thermal, radiation, and ergonomic; missing one mode means it never gets assessed, and the cobot will eventually run it [S1]. For collaborative applications the location-driven hazards are the ones most often skipped: crushing or trapping at fixed structures, and head-contact risk when the cobot base is mounted above operator standing height [S3]. Material and load data feed the same review, because payload, gripper mass, and workpiece sharpness change both impact energy and entrapment geometry [S3].
Step 3 and 4: Estimate and Evaluate Risk
For each hazard the assessment scores severity of harm (S), probability of occurrence (P), frequency and duration of exposure (F), and possibility of avoiding or limiting harm (A) [S1]. ISO 12100 does not prescribe a numeric scoring method, so the facility's chosen matrix must itself be documented and applied consistently across the cell [S1]. Each scored risk is then compared against documented tolerability criteria: acceptable as-is or move to reduction. Risks accepted without reduction still need a named sign-off, because auditors treat undocumented acceptance as a finding [S1]. The CARA methodology from Fraunhofer IPA formalises a similar flow in four semi-automated steps and is used as a reference structure for many European integrators [S6].
Step 5: Apply the Three-Step Risk Reduction Hierarchy
Reduction is ordered, not free-form: inherent safe design first, then safeguarding measures, then information and training [S1]. A warning label cannot substitute for a design change that would eliminate the hazard; ISO 12100 forbids skipping levels, and traceability from hazard to chosen measure is what auditors actually check [S1]. For collaborative operation the four collaborative modes are the engineering menu: safety-rated monitored stop, hand guiding, speed and separation monitoring, and power and force limiting; selection is driven by the contact scenarios identified in Step 2 [S1]. When power and force limiting is selected, the ISO/TS 15066 biomechanical limits govern the per-body-region force and pressure thresholds that the cell must be designed to stay under [S1]. A summary source recommends keeping the hierarchy visible on the assessment form itself, because once the document is filed, the reduction logic is the part most often challenged in audit [S7].
Comparison: Four Collaborative Modes Against Selection Criteria
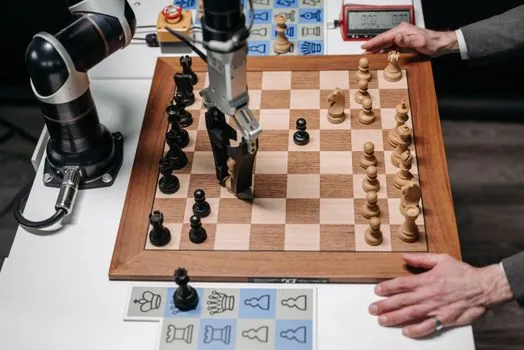
The four collaborative modes are not interchangeable; selection is driven by the Step 2 hazard list and the Step 1 use specification. [S1]
Picking the wrong mode is the most common audit finding on new cobot cells, because the mode must match both the identified hazard and the validated safety-rated hardware, not just the application description [S1][S5].
Documentation, Iteration, and Living Assessment
The risk assessment is not a one-time PDF: it must be reviewed and updated when the task, tool, workpiece, or cell layout changes, and ISO/TS 15066 explicitly states that the integrator 'shall conduct a risk assessment as described by ISO 10218 and ANSI/RIA R15.06' [S3]. Practical guides reduce this to a recurring checklist: define limits, assess tasks rather than the machine alone, apply the three-step hierarchy, and document the collaborative mode used for each task zone [S7]. Risk assessments are commonly skipped in industry because cobots have a strong safety track record over the past decade, but skipping them is what turns a non-incident into an unreportable near-miss with no traceability [S3]. For U.S. deployments the companion standard to ISO 10218-2 is ANSI/RIA R15.06, and both are typically cited together in the assessment cover page [S3].
Trackable next signal: monitor whether your integrator's assessment explicitly names ISO/TS 15066 force and pressure limits per body region; if it does not, the contact-testing scope in the next cell will be wrong, and the audit trail will not survive a customer or OSHA review [S1][S3].
For component-level specifications, see powder new material, load cell, and load cell module.
This topic is covered further in Tangential Key Pair for Reversing Flywheel Loads: Geometry, Taper, and Failure Modes.