A rotary encoder TCO analysis must price acquisition, commissioning, operation, maintenance, downtime, and replacement over the asset life cycle [S1][S3].
The assessment applies to incremental and absolute rotary encoders used for position, speed, and length feedback, with the result expressed per machine, line, or installed channel over a defined period.
What belongs in a rotary encoder TCO model
Total cost of ownership is the true cost of a capital acquisition across its life cycle, including purchasing, operating, replacement, and upgrade phases [S3]. For an encoder, the acquisition line should include the sensor, cables, mounting hardware, interface electronics where required, documentation, and freight. It should also include the engineering time required to select, qualify, and integrate the device.
The operating lines should capture inspection time, cleaning where applicable, spare-parts inventory, calibration labor, repair labor, consumables, and software or firmware maintenance. Availability risk must be converted into an annual cost or included in the financial model rather than treated as a qualitative note. A TCO framework can include direct and indirect lifecycle costs, while initial procurement price is often only one part of the economic decision [S1][S4].
Downtime has a calculable structure: production loss per hour multiplied by affected machine hours per incident, multiplied by incidents per year, plus any additional overtime, scrap, inspection, or expedited-freight cost. This method is more defensible than assigning an arbitrary downtime percentage because it uses the machine's actual rate and event history. The same principle applies to encoder-related limit switch faults when a machine combines feedback and limit-detection functions.
Cost drivers that determine the purchase-price trade-off
Purchase price is driven by sensing technology, output interface, resolution, accuracy, electrical rating, mechanical protection, mounting configuration, and certification requirements. A lower-cost encoder can still deliver lower TCO if it survives the actual environment and avoids repeated access to guarded machinery. A higher-cost sealed encoder can lose that advantage if its extra cost is not matched by fewer failures, shorter installation time, or longer maintenance intervals [S2].
Volume tier affects unit price, while integration scope affects installed cost. A device that requires additional signal-conditioning hardware, separate adapters, or custom cables cannot be compared directly with a self-contained unit on catalog price alone. Certification for a hazardous or washdown environment may add engineering, documentation, and verification expense, but the analysis must be based on the required application conditions rather than a generic assumption.
Lead time belongs in the model through working-capital occupancy, expedited freight, and the cost of delaying commissioning. Inventory coverage is another cost driver: holding a strategic spare may cost more than the encoder, while an unplanned replacement can interrupt production. The Reshoring Now estimator demonstrates the general TCO method of evaluating 30 cost and risk factors, accumulating them into categories, and producing a five-year forecast [S5]. That framework is not encoder-specific, but its structure is applicable.
Mechanical, optical, and magnetic options compared
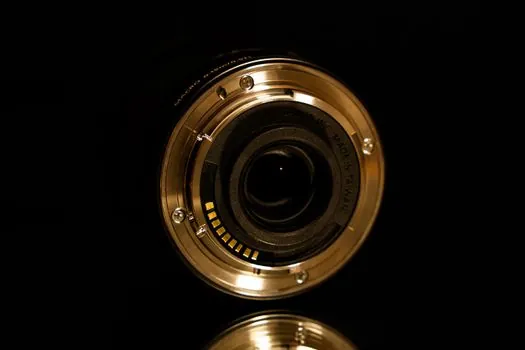
Mechanical rotary encoders are associated with simplicity, durability, and low cost, which makes them relevant where application requirements are modest [S7]. Their economic case is strongest when the required resolution and operating environment are simple, replacement is accessible, and downtime exposure is low. Their weakness is that contact wear introduces a maintenance and failure pathway that does not exist in a non-contact optical design.
Optical rotary encoders use non-contact sensing and are suited to applications requiring finer position or speed measurement, but the total cost must include cleaner mounting, compatible sensing surfaces, and careful alignment. Magnetic encoders can provide compact, cost-sensitive feedback where the required measurement performance does not demand optical resolution [S7]. The comparison should not be reduced to sensor type: resolution, accuracy, temperature exposure, contamination, shock, cable integrity, and service access determine whether the theoretical advantage becomes an installed-life advantage.
A practical decision matrix compares four criteria. First, capital cost favors the lowest compliant catalog price. Second, installation cost favors the fewest mechanical interfaces, cables, adapters, and commissioning steps. Third, ownership risk favors the design with the better documented fit for contamination, temperature, shock, and electrical conditions. Fourth, availability favors the option with credible local spares and a shorter measured replacement path. The correct choice is the option with the lowest validated life-cycle cost for that machine, not the option with the lowest price per unit.
Where sealed encoders alter the ownership calculation
HEIDENHAIN publishes guidance on reducing total cost of ownership in manufacturing [S2]. The engineering implication is narrower and more useful: sealing can reduce exposure to contaminants and mechanical wear, but only if the installed product, shaft interface, cable entry, and mounting arrangement preserve the rated protection.
For washdown, dust, coolant, or abrasive environments, a sealed encoder may reduce cleaning frequency and contamination-related failures. That benefit should be verified through the product specification and site conditions. Purchase price alone cannot establish whether the seal adds value; the calculation should compare added acquisition cost against reduced inspection labor, fewer replacement events, lower consumable use, and less production loss [S1][S2].
Sealing does not remove every failure mode. Cable flexing, poor grounding, connector damage, shaft misalignment, electrical noise, and incompatible drive electronics can still disrupt feedback. Installation quality therefore belongs in the TCO model. An encoder that is mounted correctly but receives an unsuitable output or interface creates troubleshooting and retrofit costs that no product-price comparison can reveal.
Absolute and incremental encoders serve different cost cases
An absolute encoder supplies a position value that can persist without continuous external reference, while an incremental rotary encoder produces position information through pulse counts. The selection affects both electronics and lifecycle work because absolute feedback can reduce homing-related sequencing, but that benefit depends on the control architecture and whether the application requires absolute position after a power interruption. [S1]
For a continuously referenced servo axis, an incremental encoder may provide adequate information at a lower system cost. For a machine that must establish position at startup, preserve position after a power loss, or simplify commissioning, an absolute encoder may justify its added hardware cost. The analysis should quantify commissioning labor and restart behavior rather than assume that one technology is always more efficient.
Output architecture is equally consequential. Digital position buses can reduce point-to-point wiring in suitable systems, but the complete installation must include compatible controllers, network infrastructure, configuration effort, and replacement parts. The cost of an encoder that needs an extra gateway or converter should be recorded as capital, integration, and maintenance cost. This approach follows the TCO principle that all direct and indirect costs over the life cycle can influence the best-choice decision [S1].
Installation, maintenance, and failure costs dominate the model
Installation cost includes mechanical preparation, shaft alignment, bracket and coupling work, cable routing, grounding, electrical termination, controller configuration, and functional testing. Labor hours should be recorded separately from material cost because a minor change in mounting design can alter both. A design requiring guarded-machine entry for routine setup also carries an outage effect that a bench assembly line does not have. [S3]
Maintenance should include planned inspection, cleaning, recalibration, cable and connector checks, spare-parts carrying cost, and repair response. For each failure mode, record labor hours, parts, machine hours, and the time required to restore verified feedback. A common mistake is counting only the replacement sensor while omitting the labor to identify the cause, the time to obtain a spare, and the cost of retesting the machine.
Energy consumption is usually less prominent than machine downtime, but it belongs in a complete model rather than being ignored. Include the encoder and any required interface electronics' consumption, multiplied by connected hours and the applicable electricity rate. If the control system's standby or shutdown behavior affects consumption, model that behavior explicitly. For most industrial feedback applications, availability will be a larger line item than electricity, but excluding energy makes the model incomplete [S1][S4].
How to build the comparison model
Set a fixed evaluation period and discount rate, then define the installed quantity. Use the same machine output rate, labor rate, energy rate, and incident assumptions for every candidate. Calculate acquisition cost per channel, annual operating cost, expected annual failure cost, and disposal or residual value. The Fleet Forum model identifies acquisition, operating costs, and disposal value as separate TCO elements [S4].
For each candidate, enter unit price, mounting and installation labor, commissioning hours, annual inspection hours, maintenance spending, spare inventory, expected failures, downtime cost per incident, energy use, upgrade expenditure, and residual value. Then calculate net present value over the chosen life. Do not mix purchase-basis totals with discounted future costs, and do not assign a residual value to an encoder that is not expected to be removed separately from the machine.
Validate assumptions with repair records, spare usage, machine logs, and maintenance work orders. The payoff is an auditable comparison rather than a subjective claim that one encoder is better. The rotary encoder installation guide provides the practical installation context for checking cable routing, alignment, and commissioning discipline.
Failure modes that must carry a modeled cost
Contamination, impact, vibration, excessive temperature, electrical noise, cable damage, shaft slip, and mounting misalignment can each lead to inaccurate feedback, an alarm, or an unplanned stop. The model should not combine these into an unsupported failure rate. Use observed site data where available, manufacturer qualification data when relevant, and a clearly labeled engineering assumption otherwise. [S5]
A photoelectric sensor may be acceptable for a simple presence check, but it does not replace a rotary encoder's shaft-position or speed feedback. A proximity sensor is likewise a separate device class and should not be substituted into an encoder TCO without an engineering basis. Selecting the wrong sensing function creates a false cost comparison before lifecycle expenses are even counted.
Protect the calculation from false precision. A TCO result is a decision model, not a warranty of future failure cost. Sensitivity analysis should vary the major assumptions, especially downtime hours, annual incidents, maintenance labor, discount rate, and useful life. If the ranking changes under reasonable inputs, procurement should negotiate warranty and support terms or gather better site data before claiming an encoder is the lowest-TCO option.
Procurement evidence to track after selection
A defensible encoder decision should leave five measurable records: quoted unit and installed cost, verified commissioning hours, observed maintenance interventions, failure and downtime events per year, and the measured cost or benefit of upgrades or replacements. The Reshoring Now estimator's 30-factor, five-year approach demonstrates why transparent formulas and cumulative category charts are useful for review [S5].
For operating managers, track mean time between failures, mean time to repair, number of machine-hours lost, and maintenance labor per operating hour. For procurement, track warranty exclusions, spare-part lead time, product-life commitments, and the cost of equivalent replacements. If a supplier cannot support those claims with documentation, the TCO model should use conservative values rather than favorable assumptions.
The next control point is an encoder fleet review after 12 months of operating data, followed by a full TCO update at the end of the defined evaluation period. That review should reconcile estimated failure costs with actual downtime and confirm whether the selected seal, interface, and mounting configuration remain the lowest-cost choice.