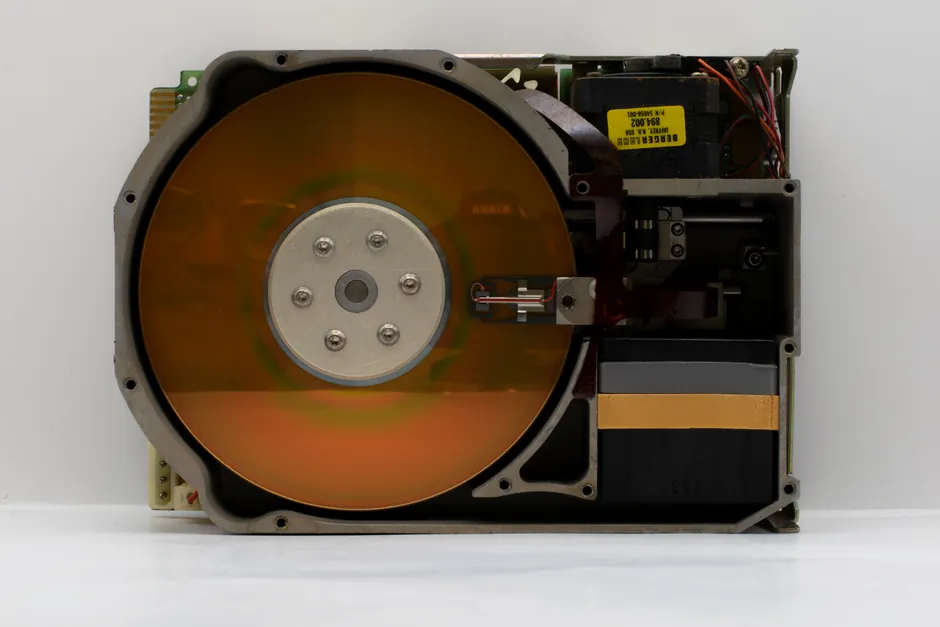
A 1024 PPR incremental rotary encoder with 5 VDC supply and RS-422 line-driver output is a stock configuration in industrial automation, pairing a 1024-pulse-per-revolution optical disk with differential A, /A, B, /B, Z, /Z channels per the RS-422A standard [S3][S5].
The "1024 PPR" label is the disk line count, not the resolver count: in quadrature decoding the receiving counter multiplies by four, giving 4096 counts per revolution, which is the figure that drives positioning resolution downstream [S2][S3]. Common applications include servo feedback, CNC spindle orientation, conveyor speed, and packaging-machine registration.
PPR, Counts, and Resolution: What 1024 Actually Means
1024 PPR is the number of pulses (lines) engraved on the optical disk per shaft revolution; each pulse is a high/low cycle on channel A, mirrored on /A as an inverted copy [S2][S3]. Phase B is offset by a 90° electrical angle from phase A, so direction is read from which channel leads, and phase Z is the once-per-turn origin pulse used for homing [S3].
With a 4x quadrature decoder, 1024 PPR resolves to 4096 counts/rev, equivalent to roughly 0.088° per count; at 1024 PPR with 1x decoding, resolution is 4096 discrete angles per revolution [S2]. Engineers often upsize to 2500 PPR or 5000 PPR when faster line counts at the same shaft speed are needed, but 1024 PPR remains the most common mid-band spec because the RS-422A line driver can comfortably transmit it up to roughly 12,000 rpm before hitting the 500 kHz response limit [S1][S5].
RS-422 Line-Driver Output: Electrical Envelope and Cable Limits
The RS-422A line-driver output uses a differential driver IC and a complementary differential receiver, making it the standard output for long-cable, high-noise encoder links [S3]. Each channel travels on a twisted pair, so 3 channels (A, B, Z) need 6 signal wires plus 5 VDC power, 0 V ground, and a shield drain, totalling 8 conductors in a typical M12 8-pin or D-sub 9-pin cable [S5].
Operating envelope: 5 VDC supply with TTL logic levels, 100 Ω typical output impedance, 100-120 Ω characteristic cable impedance, up to 200 m cable at 100 kHz output, dropping to 50 m at 500 kHz [S5]. A 120 Ω termination resistor is recommended at the receiver for runs over 50 m or frequencies above 100 kHz, otherwise reflections corrupt edges [S5]. The Omron technical guide specifies that line-driver outputs are explicitly chosen for "high-speed, long-distance data transmission" and are "strong with respect to noise" precisely because common-mode noise is rejected at the receiver [S3].
5 VDC Supply vs 5-30 VDC: Why the Voltage Range Matters
True 5 VDC encoders (such as the IHI RAW-G1024-05 and the E50S8-1024-6-L-5) require a regulated 5 V supply and assume the downstream counter or DSP runs on 3.3 V or 5 V TTL, so a logic-level shifter is needed when feeding a 3.3 V DSP like the TMS320F28335 [S6][S7]. A 5 VDC-only encoder is preferred when cable runs are short (under 5 m) and the controller is mounted in the same cabinet, because the lower supply voltage reduces driver current and EMI.
Many modern 1024-PPR encoders specify 5-30 VDC wide-range supply instead, with an internal regulator producing 5 V TTL at the line-driver outputs; this lets the same encoder run from 24 VDC PLC rails without a separate logic power supply [S8]. The 8-pin shielded-cable datasheet at Sensor Centre shows 5-30 VDC, 50 mA max consumption, 40 mA per channel output, which is the typical wide-range envelope [S8]. Choose 5 VDC when the host board is a 5 V MCU/DSP, and choose 5-30 VDC when the encoder cable lands on a 24 V PLC fast-input module.
Mechanical Package: Shaft, Flange, and Speed
Industrial 1024 PPR encoders ship in three common mechanical templates: 24 mm housing with 6 mm shaft, 40 mm flange with 8 mm shaft, and 58 mm flange with 10 mm shaft [S1]. The 58 mm series is the workhorse for servomotors, the 40 mm series for stepper feedback and small conveyors, and the 24/25 mm series for tight machine builds.
Speed ratings: small-body (24-25 mm) units typically cap at 6000 rpm, 40 mm units at 6000-9000 rpm, and 58 mm units at 10,000-12,000 rpm continuous [S1]. IP ratings from IP50 (panel-mount) up to IP67 (sealed housing) cover the environmental range, with IP65 the typical minimum for washdown-adjacent factory cells [S1]. Hollow-shaft variants (HENGSTLER RI76, FAGOR H2A-D200 at 200 mm bore) skip the coupling and slide directly over the drive shaft, with the FAGOR D200 supporting up to 42 mm through-bore [S1]. For a deeper mechanical overview, see the rotary encoder reference page.
Selection Criteria: When 1024 PPR, 5 V, RS-422 is the Right Spec
Pick 1024 PPR when positioning accuracy requirements fall between 0.05° and 0.1° per count and the controller supports 4x quadrature; the implied maximum input frequency at the controller is PPR × rpm / 60, so 1024 PPR at 6000 rpm yields 102.4 kHz, well inside the 500 kHz RS-422 envelope [S5]. Pick 5 VDC supply when the host is a 5 V MCU or DSP board, and pick RS-422 line driver when cable runs exceed 10 m or the cabinet hosts VFDs, welders, or other EMI sources [S3][S5].
Do not pick this spec for: sub-arcsecond positioning (need 20-bit absolute or 50,000+ PPR), battery-powered or wireless nodes (no 5 V rail), or 24 V-only PLC systems without an intermediate TTL converter (use a 5-30 V push-pull HTL encoder instead) [S8]. A quick comparator: optical vs magnetic incremental at 1024 PPR, optical gives sub-µm jitter and 12,000 rpm but is vulnerable to shock; magnetic tolerates dust, oil, and vibration but tops out near 6000 rpm with somewhat higher jitter. A related decision is cabling topology, which interacts with the 8 vs 16 vs 32 channel remote I/O count in the same panel.
Wiring and Termination: Getting the Differential Pair Right
Wire each channel on a twisted pair with the shield grounded only at the controller end, never at both ends, to avoid ground loops that defeat the common-mode rejection of the RS-422 receiver [S4][S5]. For 3-channel A/B/Z encoders the cable needs 6 signal wires + power + ground, usually carried on an 8-pin M12 connector with the shield on the connector body [S5][S8].
Add a 120 Ω termination resistor across the differential pair at the receiver when cable length exceeds 50 m or output frequency exceeds 100 kHz; without it, edge reflections cause double-counting at the counter [S5]. If the controller only has single-ended TTL inputs, use a 26LS32 or AM26C32 quad differential receiver IC to convert the differential A, /A, B, /B, Z, /Z signals to single-ended A, B, Z, and confirm the receiver supply is 5 V before connecting a 3.3 V DSP [S6]. For more on translating field-device signals to controller logic levels, see the spec-first approach in 8 vs 16 vs 32 channel remote I/O modules.
Failure Modes and Field-Realistic Limits
Three failure modes dominate in the field: (1) missing the inverted pairs (/A, /B, /Z) during installation, which silently kills noise immunity even though the encoder "counts correctly" on the bench; (2) unterminated long cables, which cause occasional count errors when the line driver toggles faster than 100 kHz; (3) voltage mismatch when a 5 V encoder is wired to a 24 V PLC input, which destroys the output stage within minutes [S5].
Counter-side limits: the PLC or DSP must accept the resulting pulse frequency. At 1024 PPR and 12,000 rpm the encoder emits 204.8 kHz on channel A, which exceeds the 100 kHz fast-input limit of many mid-range PLCs, so the encoder must be de-rated or a faster counter module used [S1][S5]. HEIDENHAIN's general encoder literature notes that rotary encoders are the standard measuring sensor for rotary motion and angular velocity, with the model (absolute vs incremental) selected by control-loop bandwidth and homing needs, not raw PPR [S9].
Comparable Specs and Cross-Reference Anchors
Two near-equivalent stock numbers anchor the 1024 PPR / 5 VDC / RS-422 class: the RS PRO 5V 1024 PPR line-driver incremental encoder rated 3500 rpm max, and the IHI RAW-G1024-05 1024 PPR 5 V RS-422 with quadrature A/B/Z output [S2][S7]. The Autonics E50S8-1024-6-L-5 is the same family with a 6 mm shaft and cable-outlet strain-relief, common on Asian-built machines [S6]. For higher counting resolution on the same RS-422 envelope, the ICURO RI58 reaches 10,000 lines and 40,000 steps after 4x decode, and the IH520 reaches 3,600 lines in a 52 mm housing [S1].
Look at the linear encoder reference when the application is a linear stage rather than a rotary shaft, as the electrical interface (RS-422, 5 V TTL) is the same but the resolution is quoted in µm rather than PPR. For higher PPR where the 5 V RS-422 envelope becomes the bottleneck, an alternative is to step up to 24 V HTL push-pull on a 5-30 VDC encoder with line-driver option, which trades differential noise immunity for cable length and TTL compatibility [S8].
Track these signals for the next spec revision cycle: new 1024-PPR encoder releases with integrated 120 Ω termination resistors on the PCB, and DSP reference designs that accept 5 V TTL differential directly without external 26LS32 receivers.
Detailed specification references: pile driver.