A robotic total station locks onto a prism by reflecting its infrared EDM beam back along the incoming path, and the choice between a six-corner-cube 360° assembly and a single-face circular prism directly controls how far, how fast, and how reliably the instrument can keep lock [S1][S4].
Typical robotic-spec hardware reaches about 1,500 m to a 360° prism and about 3,000 m to a standard round prism, while the round unit demands one face pointed at the instrument and the 360° unit accepts the beam from any horizontal direction [S4].
Optical construction: six corner cubes vs one corner cube
A 360° survey prism is built from six corner-cube reflectors joined into a single housing, with the six faces distributed so the EDM beam is reflected back to its source from any rotational position of the prism set [S1]. This even distribution is what gives a 360° prism similar accuracy and similar offset regardless of which side the total station is approaching from [S1].
A circular prism is a single corner cube, and the geometry only retro-reflects across a limited acceptance cone of roughly ±20° to ±30° off the face normal, which is why the operator must keep that one face aimed at the instrument [S4]. Within that cone, the single cube returns a stronger, more concentrated signal, which is the root cause of the longer working range [S4][S5].
Range, accuracy and beam deviation
Range is the headline trade-off: a typical robotic total station measures to a 360° prism out to about 1,500 m (≈5,000 ft), while a standard round prism extends that envelope to about 3,000 m (≈9,800 ft) under the same atmospheric conditions [S4]. Beam deviation on a quality 360° assembly sits in the 3–5 arc-second band (e.g. the Trimble 360° Mini Prism specification), and a typical survey-grade total station resolves distance at roughly 1.5 mm ± 2 ppm on a prism target [S1][S4].
Prism constant is the second axis you have to manage, and the two families use very different additive offsets: 360° assemblies are commonly shipped at -7 mm, 0 mm, or +2 mm depending on manufacturer (Metricop ATP1/ATP2 at -7 mm, Trimble-style 360° at +2 mm), while circular prisms cluster around -30 mm or -34 mm, with -17.5 mm and -40 mm also in widespread use [S1]. Setting the wrong constant in the total station's EDM menu is the single most common cause of systematic distance bias when swapping between a 360° and a circular prism on the same job.
Tracking behaviour on a robotic lock
360° prisms are explicitly the recommended target for instruments with automated target recognition, because they don't need constant readjustment as the pole moves and the instrument rotates, and they keep the lock alive through fast transitions between setups [S1][S3]. That is why robotic layout, machine-control prism tracking on dozers and pavers, and rapid topographic mapping default to 360° reflectors [S1][S3].
A circular prism, by contrast, is the safer pick for control traverses, deformation monitoring, and any shot where you can take the time to level, plumb, and aim the face at the instrument; the trade is more operator time per shot in exchange for a longer measurable distance and a tighter accuracy envelope [S2][S5]. Active targets, which combine a reflector stack with an electronic emitter that guides the instrument to the lock, are the third option in the Geomatics taxonomy and sit between these two on automation, but they are outside the prism-only comparison [S5].
Decision matrix: 360° vs circular for robotic tracking
Across the four criteria that drive a robotic total station spec, the comparison lines up as follows. Working range: circular wins at about 3,000 m versus 1,500 m for 360° [S4]. Tracking under motion: 360° wins, because omnidirectional reflection removes the aim constraint and survives fast pole swings [S1][S3]. Per-shot accuracy headroom: roughly equal at the EDM level (≈1.5 mm ± 2 ppm for a quality prism), but the circular prism concentrates more returned energy per shot, which gives a cleaner reading at the far end of the range [S1][S4]. Operator time per point: 360° wins, with no need to re-aim when the instrument rotates around the setup [S1][S2].
The practical rule of thumb that experienced crews apply is "use a 360° for topo and mapping shots, use a circular for everything important" [S2], which maps directly onto robotic total station workflows in mining, tunneling, and infrastructure projects where instrument lock loss is the dominant cost driver [S3].
Where the rule breaks: limitations and failure modes
Three failure modes bite if you pick by reflex. First, multipath: a 360° prism reflects from every face, so nearby reflective surfaces (shiny steel formwork, vehicle windscreens, wet concrete) can return a stronger stray signal than the prism itself and the instrument will lock onto the wrong target; a circular prism, with its narrower acceptance cone, is less prone to this in cluttered sites [S3][S5]. Second, range margin: if your control network needs 2,000 m+ sights, a 360° prism is the wrong tool and a circular prism is the only one of the two that will close the shot at the published accuracy [S4]. Third, prism constant errors: swapping a -34 mm circular for a -7 mm or +2 mm 360° without updating the EDM constant injects a 9–41 mm systematic bias into every distance on the job [S1].
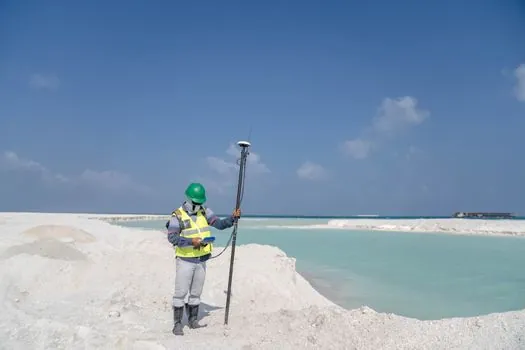
Mounting and environmental discipline matter for both. The prism must be set on a tribrach or prism pole, leveled with a bubble level, and the total station's prism-type setting confirmed in firmware before any readings are stored; this is the field procedure documented for 360° work and it applies equally to circular prisms [S3].
Spec checklist before you buy or specify
Confirm four numbers before committing: prism constant (mm), beam deviation (arc-seconds), working range to your specific total station model (m), and physical mounting (5/8" thread, tribrach, or pole-clip) [S1][S3]. Cross-check the constant against the instrument's stored prism library; most robotic total stations ship with a list of OEM constants for both 360° and circular families, and the wrong entry is the single largest source of distance bias in robotic prism tracking [S1][S3]. For long-range control work, a circular prism with a 0 or -30 mm constant and 3,000 m range is the conservative default; for robotic layout and machine control, a 360° assembly with a -7 mm or +2 mm constant and 1,500 m range is the working default [S1][S2][S4].
The next signal worth tracking is whether your instrument firmware supports active-target electronic IDs alongside passive 360° prisms, because that is the path most OEM robotic total station roadmaps are taking and it changes the constant-versus-ID decision at the EDM menu [S5].
Spec-level background on the components involved: circular saw, and weather station.
For related coverage, see Shock Absorber Sizing for Material Handling: Mass, Velocity, Force, Heat.