A total station resolves a target's three-dimensional coordinates by combining a slope distance from an Electronic Distance Measurement (EDM) module with horizontal and vertical angles from an electronic theodolite, then computing the result onboard via triangulation and trigonometry [S3][S5]. The instrument is, in effect, an integrated transiting theodolite, EDM, and microprocessor in a single housing [S3].
Working ranges in practice span roughly 0.5 m to several kilometres with a prism, while reflectorless EDM is typically limited to a few hundred metres on a cooperative surface [S2][S4]. Angular precision separates the market: high-end instruments reach 0.5 arc-seconds standard deviation, while construction-grade units sit at 5–10 arc-seconds [S3].
Core components and signal path
The total station is built around five functional blocks: a telescope for sighting, an EDM emitter/receiver pair, electro-optical angle encoders on glass discs, a tribrach with optical or laser plummet for centring, and an onboard computer with non-volatile storage [S3][S5]. The instrument is mounted on a tripod and levelled with foot screws and a plate or circular level before any shot is taken [S2][S5].
During a measurement, the EDM emits a laser or infrared pulse toward either a glass prism or a reflectorless target; the return trip is timed and converted to distance using the speed of light, with atmospheric correction applied for temperature and pressure [S1][S2][S5]. At the same instant, horizontal and vertical encoders read the absolute angle of the telescope relative to the instrument body, and the processor combines the three observables into ΔE, ΔN, and elevation for the target point [S3][S4].
EDM: how distance is actually measured
Distance measurement rests on the time-of-flight relation Distance = velocity × time, where velocity is the calibrated speed of the emitted wave through air [S5]. Two implementation paths dominate: phase-shift measurement, which compares the phase of a continuous infrared or laser carrier against the returned signal for sub-millimetre resolution at moderate range, and pulsed time-of-flight, which times a discrete laser pulse for longer ranges at lower resolution [S2][S5].
Prism-based EDM is the high-accuracy mode and is mandatory for long sights, control traverse, and deformation monitoring where millimetre-class results are required [S2][S3]. Reflectorless EDM fires at any cooperative surface, useful for façade surveys, tunnel profiles, and stockpile volumetrics, but range collapses to a few hundred metres and accuracy degrades because the returned signal strength depends on target reflectivity and incidence angle [S2][S4]. A total station used on a construction site will typically default to prism mode for layout and reserve reflectorless for as-built capture.
Angle measurement and the 0.5 to 10 arc-second split
Horizontal and vertical angles are read by electro-optical scanning of fine digital bar-codes etched on rotating glass cylinders or discs inside the instrument, an absolute encoding method that retains the reading through power cycles [S3]. The best-quality total stations resolve angles within 0.5 arc-seconds of standard deviation, which is the figure most national geodetic specifications require for first-order control [S3].
Construction-grade total stations sit at 5–10 arc-seconds and are adequate for building layout, earthworks quantities, and topographic mapping at scales of 1:500 or coarser [S3]. Collimation and instrument-axis errors are reduced in the field by running a set collection: the same angle is read in direct and reverse (plunged) telescope positions and averaged, which cancels most mechanical misalignments [S3]. This procedure is built into the onboard software and is one of the steps that pushes a 5 arc-second instrument toward its published specification in the field.
Manual versus robotic: who it is for, and who it is not
Manual total stations require a two-person crew: one sighting through the telescope and one holding the prism pole, with the operator physically turning the instrument between targets [S1][S2]. They are simple, low cost, durable, and favoured for boundary surveys, small building layouts, and control networks where throughput is not the constraint [S1][S2].
Robotic or motorized total stations carry servo drives and a radio link so the instrument can track a prism automatically and be controlled by a data collector at the rod [S1][S3]. This collapses a two-person crew to one, cuts cycle time, and reduces pointing error because the servo lock-on replaces hand aiming, making them the standard choice for high-volume commercial layout, infrastructure corridors, and monitoring campaigns [S1][S2][S3]. The trade-off is capital cost, the need for unobstructed radio between rodman and instrument, and the requirement to keep the prism in the instrument's field of view at all times.
Field workflow and integration with GNSS
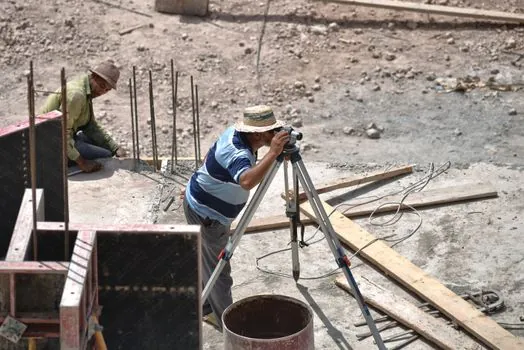
A standard total station shot follows five steps: set up over a known control point, level and orient the instrument, sight the prism or reflectorless target, record the angle and distance, and store the observation in the onboard controller for later transfer [S1][S2]. Orientation is typically established by occupying a backsight of known azimuth and zeroing the horizontal circle, after which foresights return coordinates directly [S3].
Many total stations now pair with GNSS receivers, either as separate rovers logged in the same coordinate system or as hybrid instruments that fuse total-station angles with satellite positions for non-line-of-sight sites [S1]. A field engineer reading the pressure transmitter reference will recognise the same fusion logic, where a primary high-accuracy sensor is backed by a secondary absolute-position sensor to cover the gaps. For the total station, GNSS covers open-sky areas and the total station covers urban canyons, tree canopy, and indoor or under-deck work where satellite signals fail [S1][S2].
Comparison of total station configurations
Three configurations dominate procurement decisions: manual, robotic, and reflectorless-enabled robotic. On four decision criteria the comparison is direct: angular accuracy is identical within a model line because it is set by the encoder, not the drive; range is shortest on manual-only instruments because they rarely support long-range reflectorless EDM, robotic extends prism range to 3–5 km under good conditions, and reflectorless-capable robotic units add a 200–500 m non-prism mode for as-built capture [S1][S2][S3].
Crew size separates them most clearly: a manual station needs two people, a robotic one person, and the cost premium is typically recovered within a few months on any site running more than a few hundred shots per day [S1][S2]. Power and data differ less than buyers expect, since all three use the same internal battery architecture and onboard storage, though robotic units draw more current when servos are active [S3][S5].
Limitations, failure modes, and what to check before specifying
Line-of-sight is the hard constraint: anything between the objective lens and the prism, including heat shimmer, foliage, traffic, and reflective surfaces on a prism pole, will degrade or kill the shot [S2][S3]. Atmospheric pressure and temperature must be entered into the instrument so the EDM carrier speed is corrected, otherwise a 10°C swing introduces a few parts-per-million distance error that exceeds most layout tolerances on long sights [S5].
Common failure modes in service include prism constants being set incorrectly in the controller, tribrach levelling drifting in heat, battery contacts oxidising in field storage, and encoder errors after hard knocks, all of which show up as repeatable offsets rather than random noise and are caught by shooting a known baseline before each session [S3][S5]. A flow meter or industrial valve sees the same pattern: most field disputes trace back to calibration drift or installation geometry, not to the instrument's headline accuracy figure. Readers cross-referencing the total station entry alongside related procurement guides will find the same first principle, that the published spec is only as good as the setup discipline that backs it.
The trackable signal for 2026 is the steady shift in mid-tier product lines toward standard reflectorless modules, servo lock, and 5-inch colour touchscreen interfaces that previously sat only on flagship models, plus tighter integration with GNSS rovers via Bluetooth and cloud-based controller sync, as documented in January 2026 U.S. market coverage [S2]. For specifications and field comparison, the total station encyclopedia entry collects the model-level detail; for the broader instrument family, the weather station page covers the atmospheric inputs that any EDM correction depends on.
For related coverage, see FIBC Bulk Bag Selection for E-commerce Fulfillment.